

MAUKA | Small Diameter Precision Hexapod
Payload (vertical / Horizontal )
5 kg / 2.5 kg
Linear travel range
± 10 mm
Angular travel range
± 8 °
Linear/angular resolution
0.5 µm / 5 µrad
Height middle position
198 mm
Vacuum / Cryo / Cleanroom
HV (10-6) / No / ISO 5
 Description
 Specifications
 Applications
 Pictures
 Downloads
MAUKA Small Diameter Precision Hexapod
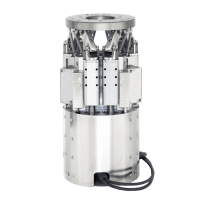
The Symetrie MAUKA hexapod is a compact, high-precision six-axis positioning system for payloads up to 5 kg, with submicrometer resolution. It provides 10 mm of travel in X and Y, 20 mm in Z and 16° in rotation, all within a diameter of 107 mm and a height of 198 mm in mid position.
A hexaglide geometry, with the motors mounted in line, keeps the diameter to a minimum. MAUKA operates in any direction, vertically, horizontally or at any angle, and is designed to hold its position even during a power failure. Absolute linear encoders give immediate position recognition, with no homing command needed each time the controller is turned back on. Axiom Optics helps you integrate MAUKA into alignment stations, beamlines and instruments.
Ø 107 mm
Hexaglide design fits six axes into tight spaces.
0.1 µm resolution
Repeatability of ±0.5 µm and ±5 µrad.
No homing
Absolute linear encoders and a mechanism that holds through power loss.
Precision Where It Matters: the Pivot Point
Every MAUKA rotation happens about a pivot point you set in software. Placing it on the optic, fiber tip or sample you are aligning keeps that point stationary while the angle changes, and determines how angular resolution translates into lateral motion elsewhere.
Angular precision at your lever arm
MAUKA rotates about a pivot point you define. Choose an axis and the distance from the pivot to your feature to see what its microradian resolution means in micrometers.
Close to the pivot, rotations move the point by nanometers: ideal for fine angular alignment.
Close to the pivot, rotations move the point by nanometers: ideal for fine angular alignment.
Far from the pivot, every microradian becomes a measurable lateral shift, so place the pivot point on the feature you are aligning.
Far from the pivot, every microradian becomes a measurable lateral shift, so place the pivot point on the feature you are aligning.
Far from the pivot, every microradian becomes a measurable lateral shift, so place the pivot point on the feature you are aligning.
Close to the pivot, rotations move the point by nanometers: ideal for fine angular alignment.
Close to the pivot, rotations move the point by nanometers: ideal for fine angular alignment.
Far from the pivot, every microradian becomes a measurable lateral shift, so place the pivot point on the feature you are aligning.
Far from the pivot, every microradian becomes a measurable lateral shift, so place the pivot point on the feature you are aligning.
Far from the pivot, every microradian becomes a measurable lateral shift, so place the pivot point on the feature you are aligning.
Small-angle geometry using Symetrie’s MAUKA resolution (2.5 µrad Rx, Ry; 3.5 µrad Rz) and repeatability (±5 µrad). The pivot point can be set anywhere in the user frame (defined relative to the machine frame) or the object frame (defined relative to the platform frame). Drawing not to scale for small angles.
MAUKA Applications
Where MAUKA fits
Fiber and photonics alignment
Align fibers, waveguides and photonic chips in six axes with 0.1 µm resolution, rotating about the coupling point so angular corrections do not disturb position.
Optics and mirror alignment
Set tip, tilt and piston of lenses, mirrors and detectors, with absolute encoders that hold the aligned position through power cycles.
Synchrotron and beamline
Position samples and optics in tight end-station spaces: the 107 mm diameter fits where larger hexapods cannot, and the platform has a 38 mm central aperture.
Space and vacuum
Symetrie lists MAUKA as clean room and vacuum compatible for instrument integration and test, with a mechanism that stays put during power failures.
Astronomy instruments
Align secondary optics, detectors and instrument modules where compact size, any-orientation mounting and repeatable positioning matter.
Choose an application.
Compare compact precision models such as SOLANO, BORA and PUNA, or browse all positioning hexapods.
A High-Performance Control Center
Controlling a parallel kinematics mechanism such as a hexapod demands fast, complex calculations to convert position instructions into motor current set points while keeping motion safe. Symetrie equips every hexapod with a high-performance control rack that works with its graphical user interface for intuitive operation and connects directly to your software environment through an optional application programming interface (API).
- A powerful multi-axis Delta Tau industrial controller.
- Drivers sized to the needs of each application.
- Input-output modules for interaction with the hexapod’s environment.
The controller adapts to different motor types (DC, brushless, stepper) and encoder technologies (absolute, incremental, linear, rotary), and is compatible with Symetrie’s optional hand-held control unit.
Choosing the Right Hexapod
Symetrie offers free HexaSym simulation software to check the travel ranges and load capacities of every hexapod in its lineup. Enter your payload, center of mass and pivot point, test different configurations, and confirm the most suitable model before you order. See the Software tab for more on HexaSym.
Want a structured walkthrough? Read the Axiom Optics Hexapod Buyer’s Guide, or explore motion and positioning hexapod applications.
MAUKA Key Specifications
- Travel Tx, Ty / Tz
- ±5 mm / ±10 mm
- Travel Rx, Ry, Rz
- ±8°
- Resolution Tx, Ty / Tz
- 0.1 µm / 0.08 µm
- Resolution Rx, Ry / Rz
- 2.5 µrad / 3.5 µrad
- Repeatability
- ±0.5 µm, ±5 µrad
- Speed
- 1.6 mm/s (Tx, Ty), 1 mm/s (Tz), 2°/s
- Payload
- 5 kg vertical, 2.5 kg horizontal
- Stiffness
- 0.7 N/µm (X, Y), 4 N/µm (Z)
- Motor and encoder
- DC motor with gearhead, absolute linear encoder
- Footprint and height
- Ø 107 mm, 198 mm (middle position)
- Platforms
- Mobile Ø 90 mm (Ø 38 mm aperture), fixed Ø 100 mm (Ø 30 mm aperture)
- Mass
- 3 kg
- Operating temperature
- 0 to +50 °C
- Controller
- ALPHA+, Ethernet, 110-240 VAC
- Environments
- Clean room and vacuum compatible
Values from Symetrie.
MAUKA FAQ
What is the MAUKA hexapod?
MAUKA is a compact, high-precision positioning hexapod from Symetrie for payloads up to 5 kg. It offers submicrometer resolution and six-axis travel within a 107 mm diameter and a 198 mm height in its middle position.
What travel ranges does MAUKA offer?
Symetrie lists ±5 mm in Tx and Ty (10 mm total), ±10 mm in Tz (20 mm total) and ±8° in Rx, Ry and Rz (16° total).
How precise is MAUKA?
Resolution is 0.1 µm in Tx and Ty, 0.08 µm in Tz, 2.5 µrad in Rx and Ry and 3.5 µrad in Rz. Repeatability is ±0.5 µm in translation and ±5 µrad in rotation.
How does MAUKA stay so small?
MAUKA uses a hexaglide geometry, with its motors mounted in line, which minimizes the diameter to 107 mm while keeping six degrees of freedom.
Can MAUKA be mounted at any angle?
Yes. MAUKA operates vertically, horizontally or at any angle, carrying 5 kg vertically or 2.5 kg horizontally, and its irreversible mechanism holds position even during a power failure.
Does MAUKA need homing after power-up?
No. Absolute linear encoders give immediate position recognition, so no homing command is needed each time the controller is turned back on.
What controller does MAUKA use?
MAUKA runs on Symetrie's ALPHA+ control rack with a multi-axis Delta Tau industrial controller, drivers sized to the application and input-output modules. It connects over Ethernet, works with Symetrie's GUI and an optional API, and supports an optional hand-held control unit.
Is MAUKA vacuum compatible?
Symetrie lists MAUKA as compatible with clean room and vacuum environments. Contact Axiom Optics to confirm the configuration for your vacuum level and cleanliness class.
Align with MAUKA
Tell Axiom Optics your payload, travel and the point you need to rotate about. We will confirm MAUKA and configure the controller for your setup.
-

The MAUKA hexapod with the glue box interface that will attach a mirror to a space telescope.
-

The MAUKA hexapod with the glue box interface that will attach a mirror to a space telescope.
-
Intuitive Hexapod Control with SYM_Positioning
Thanks to an ergonomic Human Machine Interface (HMI), SYM_Positioning hexapod positioning and control software provides simple commands accessible from the home screen, allowing for easy operation. The software also enables the generation of complex movement sequences using specific files. Additionally, the center of rotation can be easily adjusted within the software, offering flexibility for various applications.
SYM_Positioning allows:
■ Safe movement control
■ Position display in real time
■ Generate position sequences
■ The configuration of the center of rotation
■ Configure repositories (coordinate systems)
■ Configuration of limits (position, speed …)
■ API (Application Programming Interface)
■ To be interfaced in C, LabVIEW, EPICS, SPEC, TANGO, Python, Matlab …
Customization
Symétrie has the knowledge and expertise in software development, which means they can tailor software to your specific needs.


Hexasym Simulator
How to choose your hexapod?
Thanks to Symetrie’s free simulation software, you can easily check the possible travels and load capacities of each of their hexapods. HexaSym allows you to select the best solution for your application and test a variety of possible configurations.
Testing several parameters
With the HexaSym simulator, you can test cumulative travel ranges on several axes at the same time, including the “worst cases” of your applications. You can also change the center of rotation, define different reference frames, vary the orientation of the hexapod (vertical, horizontal, other) and the payload.
It includes a 3D visualization feature that lets you see how the hexapod moves according to commanded positions, along with sliders for immediate movement control
And for specific hexapods
You can also use HexaSym for specific hexapods, for which Symetrie will provide you with a configuration file compatible with the simulator.


