

AQUILON | Large Amplitude Motion Hexapod
Travel Range Tx, Ty & Tz (mm)
±800 / ±800 / ±650
Travel Range Rx, Ry & Rz (°)
±40 / ±40 / ±40
Speed Tx, Ty & Tz (mm/s)
±1,800 / ±1,800 / ±1,600
Speed Rx, Ry & Rz (°/s)
±200 / ±200 / ±100
Acceleration Tx, Ty & Tz (mm/s²)
±7,000 / ±7,000 / ±7,000
Acceleration Rx, Ry & Rz (°/s²)
±1,200 / ±1,200 / ±600
Payload (max.)
6,000 kg
Options
Outdoor / ATEX / API / ERTT
 Description
 Specifications
 Applications
 Pictures
 Downloads
AQUILON large amplitude hexapod, in a nutshell
A hexapod is a platform with a parallel structure that facilitates motion across six degrees of freedom (DOF), making it suitable for testing and calibrating systems or simulating dynamic environments.
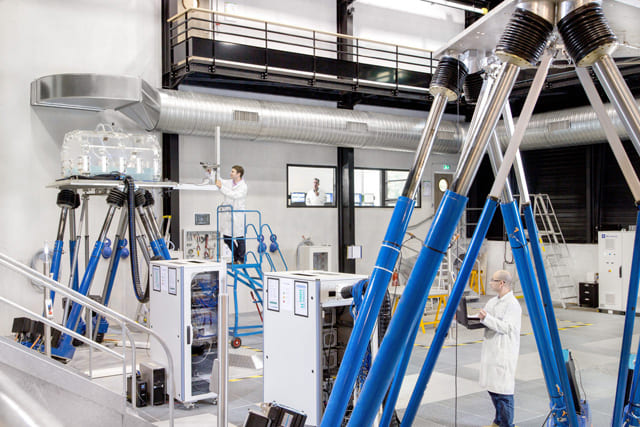
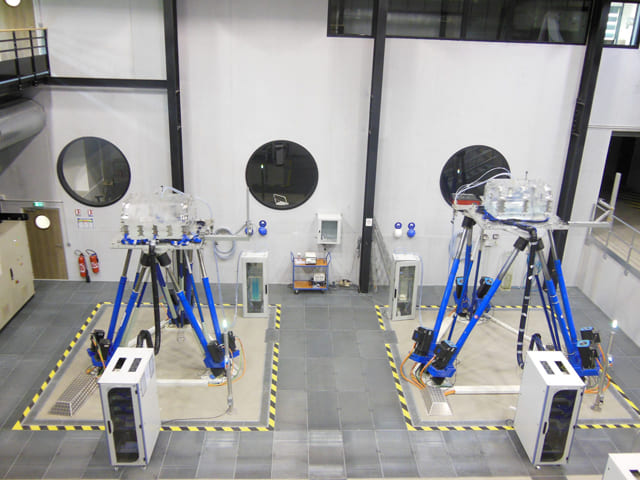
AQUILON hexapod has the largest payload capability as well as travel range (movement amplitude) capability in our product range. It is capable of moving up to 6,000 kg payloads for the standard version, and even up to 10,000 kg payloads for the boosted model, with large amplitude, high speed and high acceleration. It is heavily used in the naval industry, for sloshing test and heavy swell simulation.
It can also be paired with a measuring hexapod to monitor the motion of the actuators and the mobile platform’s movements.
AQUILON large amplitude hexapod, in more details
Choosing the right hexapod for you
Symetrie offers a free software, HexaSym, designed to simplify the process of checking the travel ranges and load capacities of each hexapod in their lineup. HexaSym enables you to select the most suitable product for your application and test various configurations. See the “software” tab for more information on HexaSym. Click HERE to download HexaSym
For more information on applications for motion & positioning hexapods, visit our application page.
Applications examples for the AQUILON hexapod:
Defense:
- Vehicle simulator (tank)
Naval:
- Sloshing testing
- Swell simulation
- Submarine simulator
Research & Engineering:
- Structural R&D
-

AQUILON Hexapod for Tossing Test
-
AQUILON Hexapod for Wave Simulation
-
10 Tons AQUILON hexapod for Sloshing Test
-
SIROCCO & AQUILON Hexapods for Sloshing Tests
-
SIROCCO & AQUILON Hexapods for Wave Simulation