MISTRAL | Large Payload Motion Hexapod
Payload Capacity
2000 lbs
Acceleration
1 g
Maximum Speed
1 m/s (2 m/s in option)
Accuracy
0.5 mm
Height in Middle Position
~1440 / ~ 1765
Dynamic Motion Simulation for Large Payloads
The Mistral hexapod is a dynamic system offering 6 degrees of freedom (6 DOF). Equipped with efficient mechanical components, it can generate motion for loads up to 1 ton, with important linear and angular travel ranges (up to ±460 mm and ±40°, respectively).
Originally designed to perform heave motion tests on boat hulls, the Mistral hexapod is also capable of replicating the movements of land, naval, or air vehicles. This capability allows for laboratory testing of sensors, SATCOM antennas, and electro-optics systems before they are installed on board.
Choosing the right hexapod for you
Symetrie offers a free software, HexaSym, designed to simplify the process of checking the travel ranges and load capacities of each hexapod in their lineup. HexaSym enables you to select the most suitable product for your application and test various configurations. See the “software” tab for more information on HexaSym.
Click HERE to download HexaSym
For more information on applications for motion & positioning hexapods, visit our application page.
1
2
3
4
5
6
7
8
9
10
11
12
13
14
| Motion & Positioning | ||
|---|---|---|
| Model | MISTRAL 600 | MISTRAL 800 |
| P: 1000 kg payload | V: 500 kg payload | P: 1000 kg payload | V: 500 kg payload | |
| Travel range Tx, Ty (mm) | ± 400 | ± 460 |
| Travel range Tz (mm) | ± 300 | ± 400 |
| Travel Range Rx, Ry (deg) | ± 30 | ± 30 |
| Travel Range Rz (deg) | ± 40 | ± 40 |
| Speed Tx, Ty (mm/s) | 1000 | 1200 | 1000 | 1200 |
| Speed Tz (mm/s) | 600 | 1000 | 600 | 1000 |
| Speed Rx, Ry (°/s) | 50 | 100 | 50 | 100 |
| Speed Rz (°/s) | 70 | 140 | 50 | 100 |
| Acceleration Tx. Ty, (mm/s²) | 5000 | 8000 | 5000 | 8000 |
| Acceleration Tz (mm/s²) | 6000 | 8000 | 6000 | 8000 |
| Acceleration Rx, Ry (°/s²) | 500 | 800 | 500 | 800 |
| Acceleration Rz (°/s²) | 700 | 1100 | 700 | 1100 |
| Diameter | 2278 mm |
1
2
3
| Mechanical Properties | ||
|---|---|---|
| MISTRAL 600 | MISTRAL 800 | |
| P: 1000 kg payload | V: 500 kg payload | P: 1000 kg payload | V: 500 kg payload | |
| Payload Capacity (kg) | 1000 | 500 | 1000 | 500 |
| Controller | |
|---|---|
| Interface | Ethernet |
| Power Supply | 400 VAC (three-phase) / 32 A |
1
2
3
4
5
6
7
8
| Miscellaneous | ||
|---|---|---|
| Model | MISTRAL 600 | MISTRAL 800 |
| P: 1000 kg payload | V: 500 kg payload | P: 1000 kg payload | V: 500 kg payload | |
| Operating Temperature Range (°C) | 0 to + 50 | 0 to + 50 |
| Size Mobile Platform (mm) | Ø 1 386 | Ø 1 386 |
| Height in Middle Position (mm) | ~1440 | 1765 |
| Mass (kg) | ~400 | ~450 |
| Cable Length | 10 | 10 |
| Options | IP 64x motor protection, Acquisition and storage of motions, API, Customized platform design | IP 64x motor protection, Acquisition and storage of motions, API, Customized platform design |
MISTRAL Applications
- Automotive
- Defense
- Energy
- Naval
- Research and Engineering
-
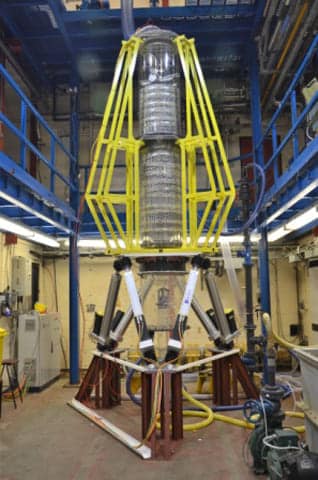
Hexapod enabling the movement of a test column at Heriot-Watt University in Edinburgh for TOTAL
-
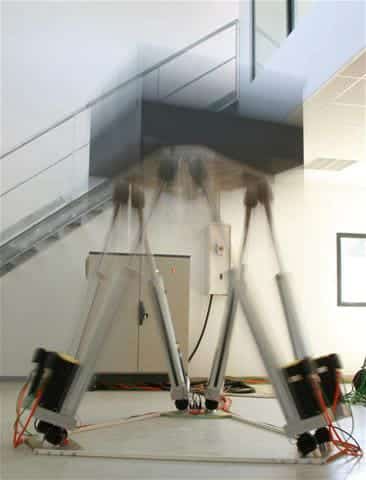
MISTRAL hexapod motion
-
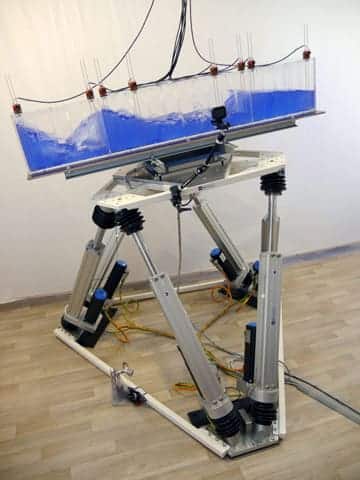
Hexapod MISTRAL wave simulator at HOPPE MARINE ©HOPPE MARINE
-
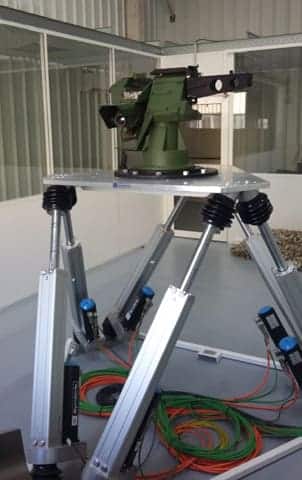
Hexapod MISTRAL to test a turret at PANHARD
-
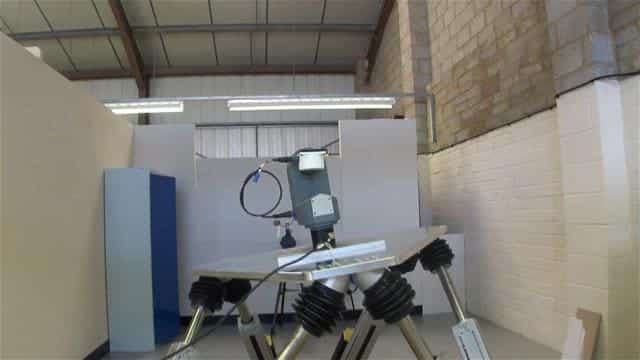
Mistral Hexapod simulating vehicle movement for in-car cameras - INSTRO
-
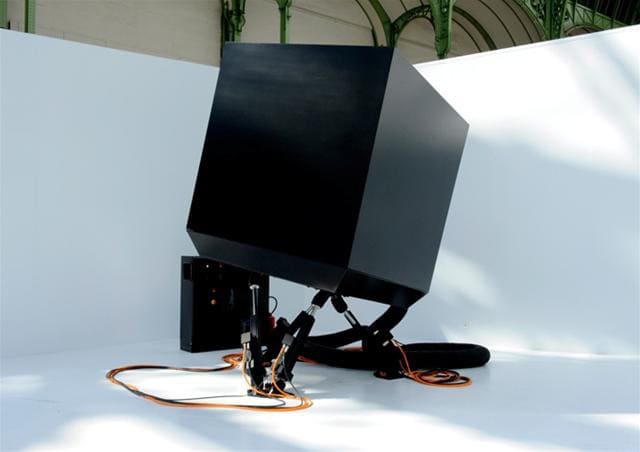
Bordeaux Engineering and Mechanics Institute I2M - ENSAM - Surfsession
-
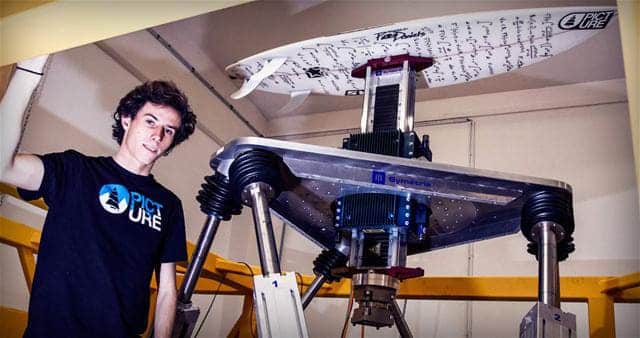
Bordeaux Engineering and Mechanics Institute I2M - ENSAM - Surfsession
-
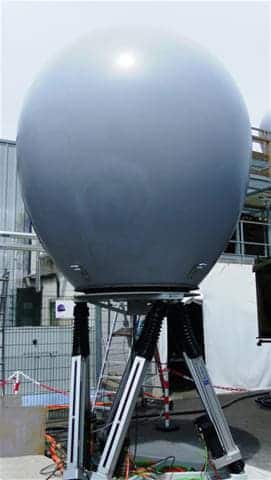
Motion simulation to qualify SATCOM antenna positioners - Courtesy of THALES Communications & Security.
-
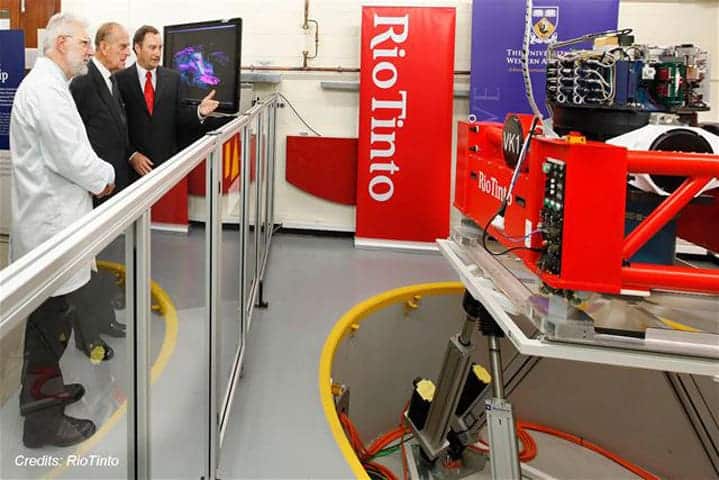
MISTRAL Hexapod for Rio Tinto with Prince Philip
-
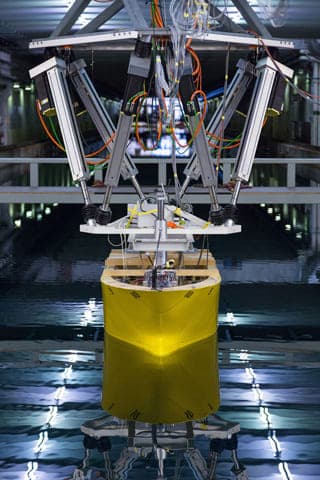
Hexapod MISTRAL in the test tank of SINTEF (Norway)
-
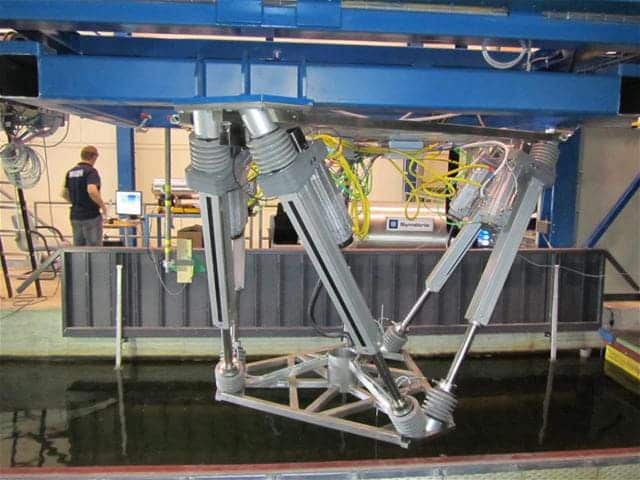
Vacuum compatible Hexapod Mistral at MARIN (Netherlands) for depressurised test tank
-
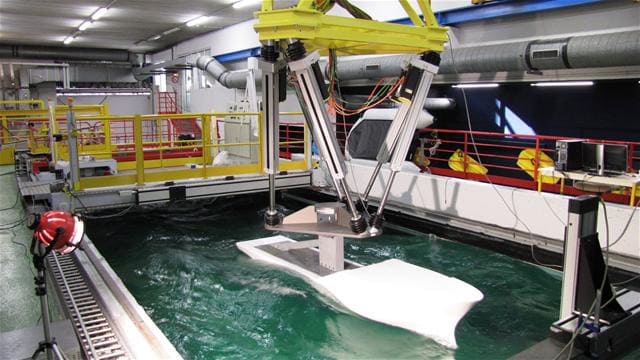
MISTRAL Hexapod with boat model at the Ifremer test basin in Boulogne sur Mer
Simple Software for a Complex Machine
The SYM_Motion movement software allows you to control the movements of a dynamic hexapod on the basis of complex algorithms. It transforms the movements desired in the 6 degrees of freedom into useful information for each of the motors.
The software is simple and ergonomic so that operators can easily use the system.
SYM_MOTION Allows:
■ Position display in real time
■ Position the hexapod
■ The generation of sinusoidal and harmonic trajectories
■ To reproduce trajectories from recordings
■ The configuration of the center of rotation
■ Validate the trajectories in complete safety for the hexapod and its loading
Options
■ Acquisition: the possibility of retrieving the position of the hexapod from information from the absolute encoders of the motors, in real time or in post-processing
■ ERTT: External Real Time Trajectory, to control the hexapod in real time, for example via a joystick (ERTT requires the API option)
■ API: the possibility of going through a software interface other than SYM_Motion to control the hexapod