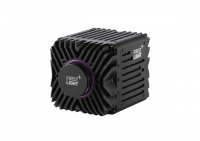
C-RED 3 | Low SWaP Uncooled High-Speed SWIR camera
Sensor Type
InGaAs
Resolution
640 x 512 px, 0.33 MP
Pixel pitch
15 µm
Shutter Mode - Frame rate full frame
Global - 602 Hz
Readout Noise
<50 e- (high gain, CDS)
Interface
USB3.1 or CameraLink (Full)
SDK
Windows 10, Linux Ubuntu 16.04 LTS and Ubuntu 18.04 LTS, ARM (for Jetson Tx2, Nano, Xavier NX and Xavier AGX)
API
C, C++, Python, LabView, MATLAB + µManager plug-in
C-RED 3 – High speed SWIR camera
Specially designed for short exposure times applications, C-RED 3 is the fastest VGA uncooled camera for short wave infrared (SWIR) imaging.
C-RED 3 is using a TEC-less 640 x 512 InGaAs PIN Photodiode detector with 15 μm pixel pitch for high resolution, which embeds an electronic shutter with integration pulses shorter than 1 μs.
Operating from 0.9 to 1.7 µm, C-RED 3 is also capable of windowing down for higher frame rate. Multiple on-board functionalities are offered such as user configurations, NUC tables, adaptive bias and HDR mode.
Autonomous, ultra compact and perfect for stable temperature environments, C-RED 3 expands the C-RED family, offering a solution for every application and every budget.
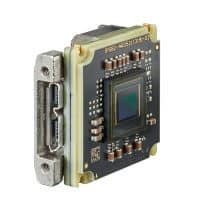
C-RED 3 can also be supplied as OEM. Some applications include free space optical telecommunications (FSO), wavefront sensing camera, laser guide star, high-speed imaging, tracking etc.
The graph below shows the total noise (readout noise + dark current contribution) at different temperatures and exposure times.

First Light Vision GUI
First Light Vision Embedded Web Interface
Reasons to chose C-RED 3
- FASTER: C-RED3 is the fastest SWIR InGaAs in its category with 600FPS full frame.
- LOW NOISE: C-RED3 offers <50e- of readout noise for high sensitivity.
- HIGH DYNAMIC RANGE WITH HDR MODE: 93 dB of linear dynamic range and true 16-bit images. Enhance your vision with the HDR module enabled at full frame rate.
- LOW SWaP: Affordable OEM version available for easy integration in complex systems.
- UNIQUE ADAPTIVE BIAS: The adaptive BIAS correction allows to use the uncooled C-RED 3 in a variable temperature environment.
- COMPREHENSIVE SDK: Each camera comes with a GUI and free SDK to develop your own solution under Linux, Windows and Jetson. Plug-ins are available for: μManager, Labview, Python, C, C++, and more.
| Sensor Specs | |
|---|---|
| Sensor type | InGaAs |
| Resolution (pixels) | 640 x 512 |
| Max frame rate full frame | 602 Hz |
| Windowing | Rows & columns |
| Max fps | 32,066 Hz in 32 x 4 px |
| Min exposure time | 165 ns |
| Full Well Capacity (e-) | ~1.2M (low gain); ~120k (med gain); ~35k (high gain) |
| Dynamic Range | ~90 dB linear in HDR mode |
| A/D converter | 14-bit |
| Lens interface | C-mount, CS-mount, T-mount |
| Cooling | TEC-less |
| Noise figures | |
|---|---|
| Readout noise | <50 e- (high gain) |
| Dark current | ~100k e-/s @ +20ºC |
| Mechanical, Electrical and Operational specs | |
|---|---|
| Interface | USB 3.1 or CameraLink (full) |
| Synch | LVTTL (5V tolerant) |
| Dimensions (mm²) | HL 55 x W 55 x L 60 |
| Weight (kg) | 0.230 |
| Power consumption | 6.5W typical |
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
16
17
18
19
20
21
22
23
24
25
26
27
28
29
30
31
32
33
34
35
36
37
38
39
40
41
42
43
44
45
| FPS table (14-bit depth) - Granularity = 32 x 4 px | ||||||
|---|---|---|---|---|---|---|
| 32 | 64 | 128 | 256 | 512 | 640 | |
| 4 | 32,066 | 31,512 | 30,458 | 28,548 | 25,367 | 24,029 |
| 8 | 28,108 | 27,348 | 25,945 | 25,532 | 19,840 | 18,397 |
| 16 | 22,542 | 21,631 | 20,015 | 17,413 | 13,819 | 12,526 |
| 32 | 16,147 | 15,254 | 13,736 | 11,455 | 8,599 | 7,646 |
| 64 | 10,302 | 9,596 | 8,440 | 6,801 | 4,898 | 4,297 |
| 128 | 5,975 | 5,509 | 4,765 | 3,752 | 2,632 | 2,291 |
| 256 | 3,247 | 2,975 | 2,547 | 1,978 | 1,367 | 1,184 |
| 512 | 1,697 | 1,549 | 1,319 | 1,016 | 697 | 602 |
| Frame grabber compatibility (for CameraLink only) | |
|---|---|
| Brand | Model |
| EDT | Vision Link F4 Camera Link® (supplied by Axiom) |
| Euresys | Grablink Full (supplied by Axiom) |
| Matrox® | Radient eV-CL Camera Link® |
| Teledyne Dalsa | Xtium2-CL MX4 |

High speed SWIR camera Applications
- Night Vision
- Long Range Surveillance And Tracking
- Active Imaging
- Cloud Or Smoke Penetration
- Background Contrast
- Solar Cells Inspection
- Semiconductor Inspection
- Quality Control
- Production Control
- Non Destructive Inspections
- Environmental Monitoring
- Secure Laser Communication
- Astronomical Observations
- Adaptive Optics
- Overpainting
- Non Destructive Analysis
- Erased Marking
- Counterfeiting
- Carbon Black Using
- Alteration Identification
C-RED 3 High speed SWIR camera Software
In order to run First Light Imaging software, the recommended minimum system requirements are the following :
RAM :Â 8Go minimum, more for C-BLUE One UV
Processor : Intel® CoreTM i5 or higher
Screen resolution :Â at least 1920 x 1080
First Light imaging software is cross-platform :
Operating system
- Windows® 10 & Windows® 11
- Linux® Ubuntu 16.04 LTS, 18.04 LTS & 20.04 LTS
- NVIDIA® Jetson Tx2, Xavier NX and Nano (only with USB 3 interface)
- CentOS 7.9
SDK Plug-ins
- Matlab
- LabVIEW
- µManager
- Python
Cooling plate for C-RED 3